
Sogang University · Mechanical Engineering
Building the hardware of
physical intelligence
The Robotics & Intelligent Mechanisms Lab develops core robotic hardware and physical intelligence for dexterous interaction with the real world — robot hands, grippers, compact high-performance actuators, variable transmissions, and proprioceptive, force-aware manipulation.
Latest Updates
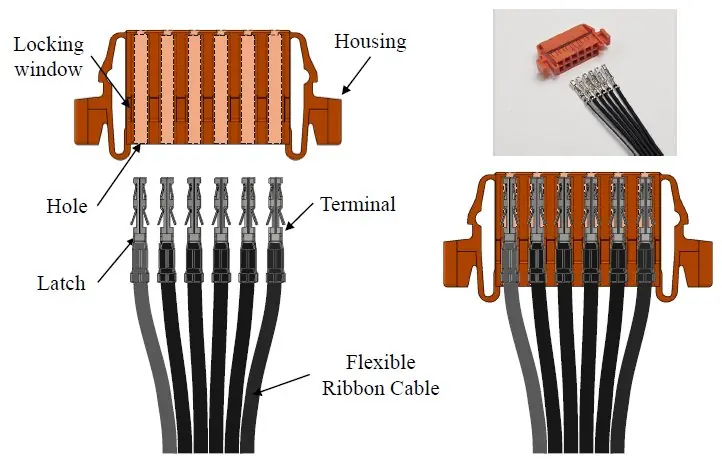
All updates →- Patent application filed: automated assembly system for two-row flexible ribbon harness cables (KR 10-2026-0195251)Patent2026.10.26
- Korean patent granted for the lower-limb force assistance device (KR 10-2980945, with NRC and Sejong Univ.)Patent2026.10.25
- New videos: RIM Hand Test 1 & 2Video2026.10.16
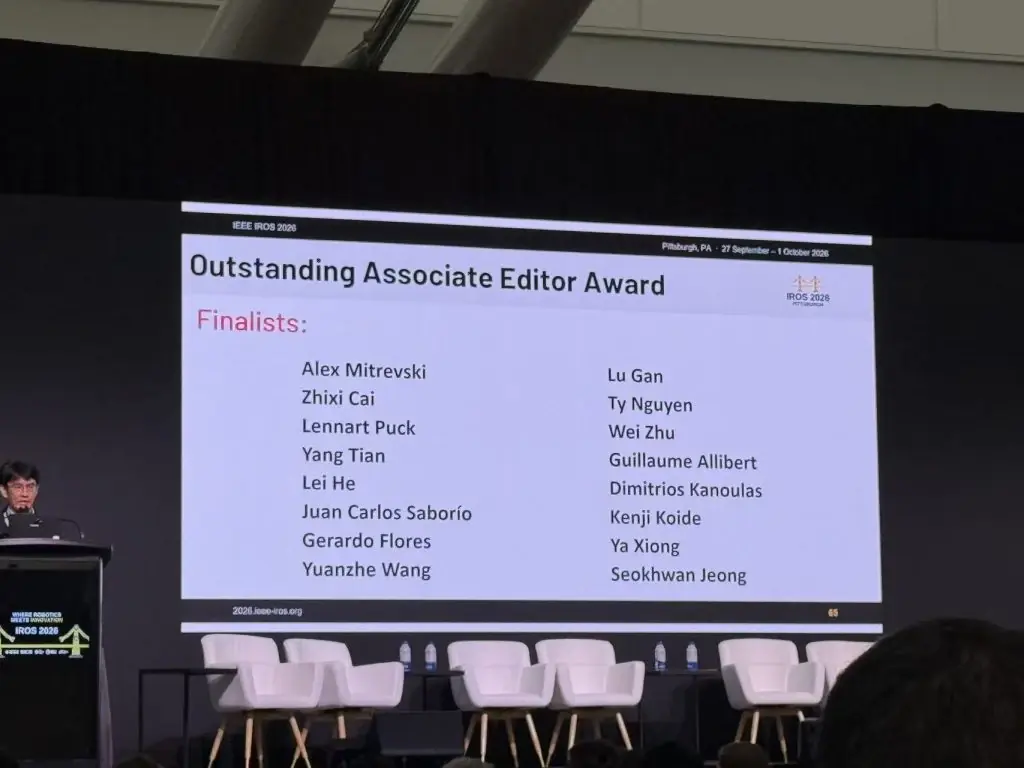
- Prof. Jeong named a finalist for the IROS 2026 Outstanding Associate Editor AwardAward2026.10.13
- Prof. Jeong to give an invited talk at KSRM 2026, Seoul (Oct 23)News2026.10.12
Research
What moves, grasps, and understands force
In Motion
Selected experiment videos
DDD Gripper — Direct-Drive Differential Multi-DOF Robotic Gripper
GripperVision-Free Multifingered Blind Grasping Using Uniaxial Fingertip Force Sensing
Physical AIResearch Playlist · 27 videos
RIM Hand Test 2
RIM Hand Test 1
Simple Torque-Observation Alignment for Zero-Shot Sim-to-Real Grasping with a Direct-Drive Gripper
Automated Terminal-to-Housing Assembly System for Flat Ribbon Cable Harness
Modeling and Control of a 2-DoF Meso-scale Continuum Robotic Tool for Pediatric Neurosurgery
Patient-specific, Voice-controlled, Robotic FLEXotendon Glove-IISystem for Spinal Cord Injury
Ultra-Low-Impedance, High-Control Bandwidth, and High-Sensitive Robotic Finger Demo 1
A Robotic Hand with an Accurate Carpometacarpal Joint and Nitinol-Reinforced Skeletal Structure
Twisted String Actuation Module for Bi-directional Compact Robotic Finger
서강대학교 이에드가 “Robust Hand Manipulation Policy Based on RL-DOB”
Progress update on blind grasping research
Blind Grasping 2nd Trial
Flex RIM hand - 1st prototyping
A Robotic Finger with a 4-bar Linkage-based Compact and Continuously Variable Active Transmission
Coaxial Magnetic Gear-based Tool-Changing System
Hand Exo with Suction Cup
Continuously Variable Transmission and Stiffness Actuator based on Actively Variable FourBar Linkage
Magnetic Gear-based Actuator: A Framework of Design, Optimization, and DOB-based Torque Control
Development of High-Performance Humanoid Prosthetic Hand System
Prosthetic Robot Hand controlled by EMG –Twisted String Actuation, Box and Block Test(BBT)
MSC Prosthetic hand prototype EMG-based grasping intention estimation experiment
Mechanical Variable Magnetic Gear Transmission
Robot Gripper and Robot hand using 2-Speed Twisted String Actuation (TSA)
Active Dual-mode Twisting Actuation Mechanism
Robot hand with 2-speed transmission mechanism based on twisted string actuation
AIM 2016 720p
Designing Anthropomorphic Robot Hand with Active Dual-Mode Twisted String Actuation Mechanism
Lab News
Latest from the lab
Join Us
Build robots that touch the real world
Now recruiting
How to apply
Apply through the application form — every submission is reviewed, so please do not send applications by email.
Applications sent by email can easily be missed, so please use the Application Form above. Only if special circumstances prevent you from using the form, email Prof. Seokhwan Jeong (seokhwan@sogang.ac.kr) and briefly explain why.
Undergraduate internships are open to students who hope to join RIM Lab for graduate study or who want to explore graduate study here, and are arranged individually; requests made only for general research experience (including another university’s internship requirement) are not accepted. Our weekly open lab meeting is open to anyone without prior permission — email the lab manager to ask when the next one is, and come see what we build.