
Research Projects
Compact Variable Transmission
Actuators that shift gear like machines should — compact CVT/VTM modules for dynamic robots.
Overview
Robots must be both fast and strong, but a fixed gear ratio forces a trade-off between speed and torque. We develop compact variable transmission mechanisms (VTM) that dynamically adjust the torque–speed ratio inside the actuator itself.
Our implementations span twisted-string-based automatic transmissions, actively variable four-bar linkage CVTs with controllable stiffness, and their applications to robotic fingers, hands, and legs for highly dynamic tasks.

Demonstrations
CVT & Stiffness Actuator based on Actively Variable Four-Bar Linkage
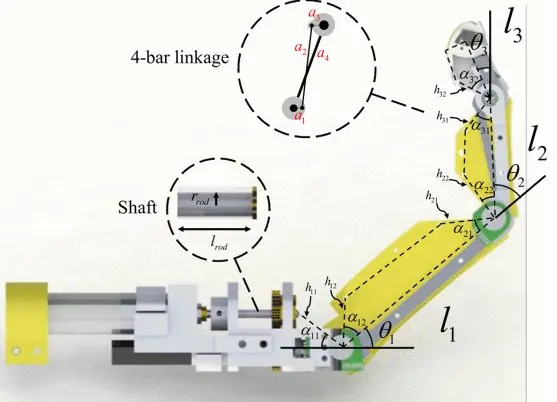
Robotic Finger with 4-bar Linkage-based Continuously Variable Active Transmission
Twisted String Actuation Module for Bi-directional Compact Robotic Finger
Robot Gripper and Robot Hand using 2-Speed Twisted String Actuation
2-Speed Small Transmission Based on Twisted String Actuation and a Dog Clutch
Ph.D. work at KAIST
Robot Hand with a 2-Speed Twisted String Transmission
Ph.D. work at KAIST
Active Dual-Mode Twisting Actuation Mechanism
Ph.D. work at KAIST
Robotic Finger with Active Dual-Mode Twisting Actuation — AIM 2016 Best Student Paper
Ph.D. work at KAIST
Representative Publications
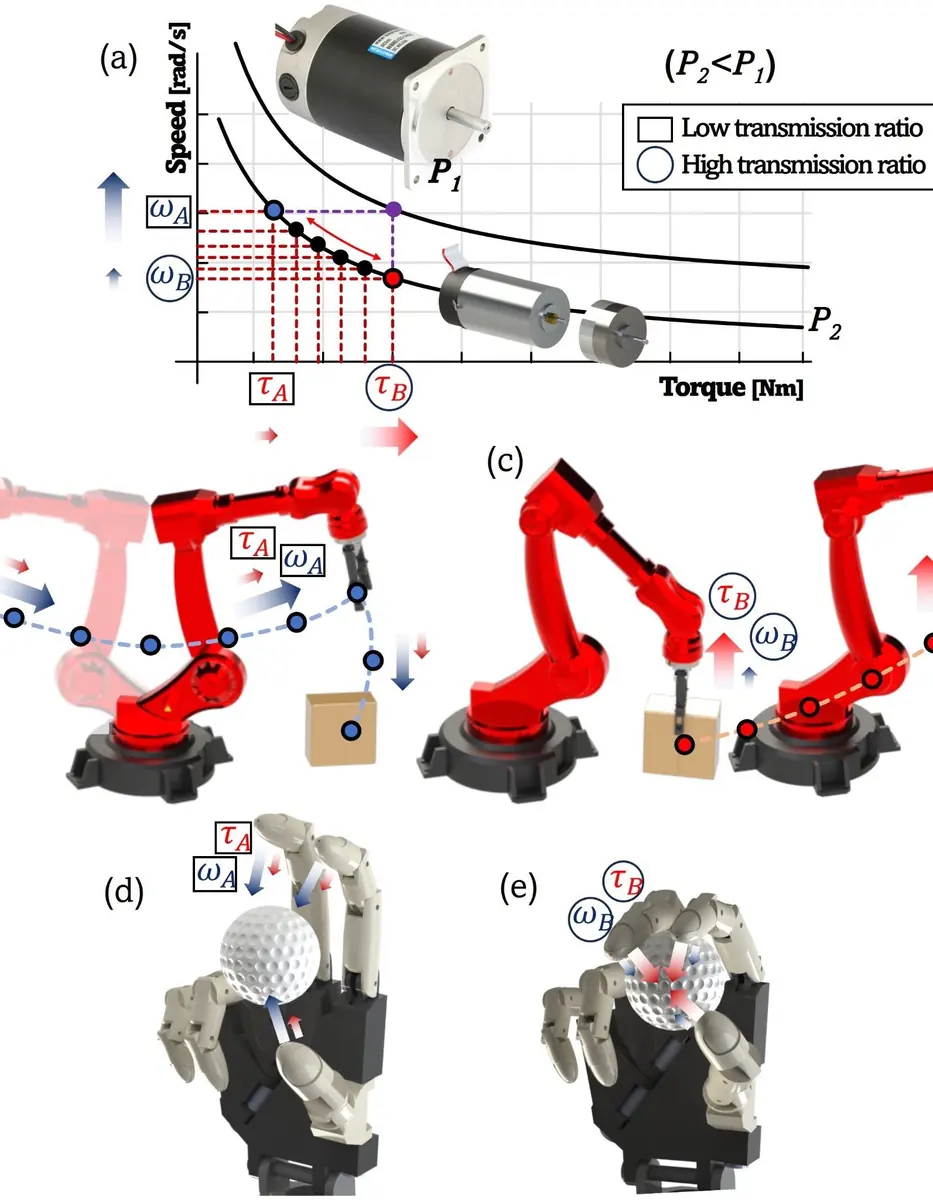
Variable Transmission Mechanisms for Robotic Applications: A Review
J. Park*, J. Lee, H.-T. Seo*, S. Jeong*
IEEE Robotics and Automation Magazine · 2025
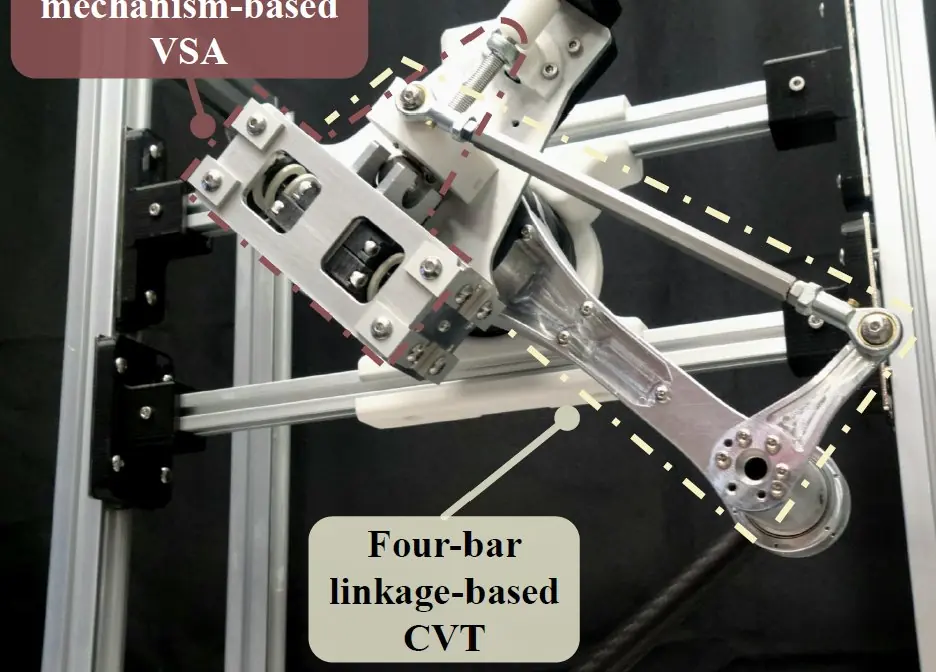
J. Hur, H. Song, S. Jeong*
IEEE Robotics and Automation Letters · 2024
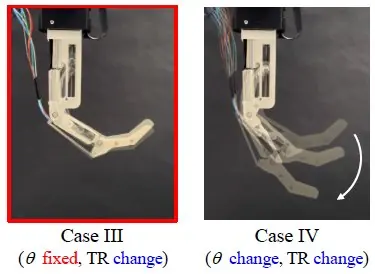
A Robotic Finger with a 4-bar Linkage-based Compact and Continuously Variable Active Transmission
S. Chung, E. Sohn, S. Jeong*
IEEE Robotics and Automation Letters · 2024
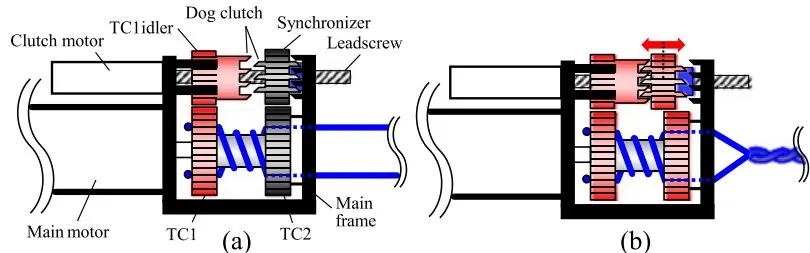
A 2-Speed Small Transmission Mechanism Based on Twisted String Actuation and a Dog Clutch
S. H. Jeong, K.-S. Kim
IEEE Robotics and Automation Letters · 2018
S. H. Jeong, K.-S. Kim, S. Kim
IEEE AIM · 2016
Patents
- Actively variable stiffness and transmission mechanism based on a 4-bar linkage for robotsFiledUS 19/265,263 · KR 10-2025-0053062 · KR 10-2024-0094442 (legged robot)
- Dual-mode transmission mechanism based on twisted string actuation ↗RegisteredUS 15/806,466 · EP 17200917.7 · KR 10-2017-0032997 · PCT/KR2017/012387
- Dual-mode actively variable twisted string actuator and robotic finger ↗RegisteredKR 10-2014-0180017
Funding
- NRF LINC Industry-Academia Joint Project — RL protocols and hardware for quadruped-robot mobility over varied terrain (joint)