
Research Projects
Surgical Robots
Steerable meso-scale robots for neurosurgery and endovascular intervention.
Overview
Minimally invasive surgery demands dexterity at millimeter scale. During and after his time at Georgia Tech, Prof. Jeong developed steerable surgical robots including the COAST guidewire robot for endovascular intervention, robotically steerable catheters for mitral valve implant delivery, and meso-scale continuum tools for pediatric neurosurgery.

Demonstrations
COAST: Coaxially Aligned Steerable Guidewire Robot
Work performed at Georgia Tech (Desai Lab) · © 2020 IEEE
2-DoF Meso-scale Continuum Robotic Tool for Pediatric Neurosurgery
Work performed at Georgia Tech (Desai Lab) · © 2021 IEEE
Representative Publications
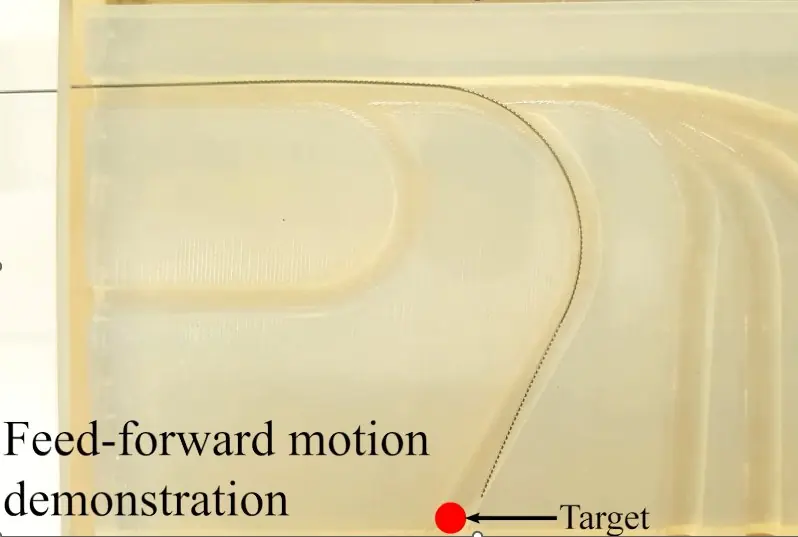
Design, Modeling, and Control of a Coaxially Aligned Steerable (COAST) Guidewire Robot
S. Jeong, Y. Chitalia, J. P. Desai
IEEE Robotics and Automation Letters · 2020
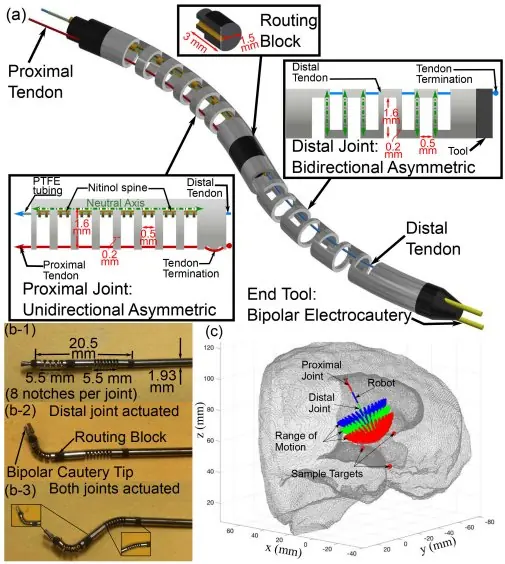
Modeling and Control of a 2-DoF Meso-scale Continuum Robotic Tool for Pediatric Neurosurgery
Y. Chitalia, S. Jeong (co-first), K. Yamamoto, J. Chern, J. P. Desai
IEEE Transactions on Robotics · 2021
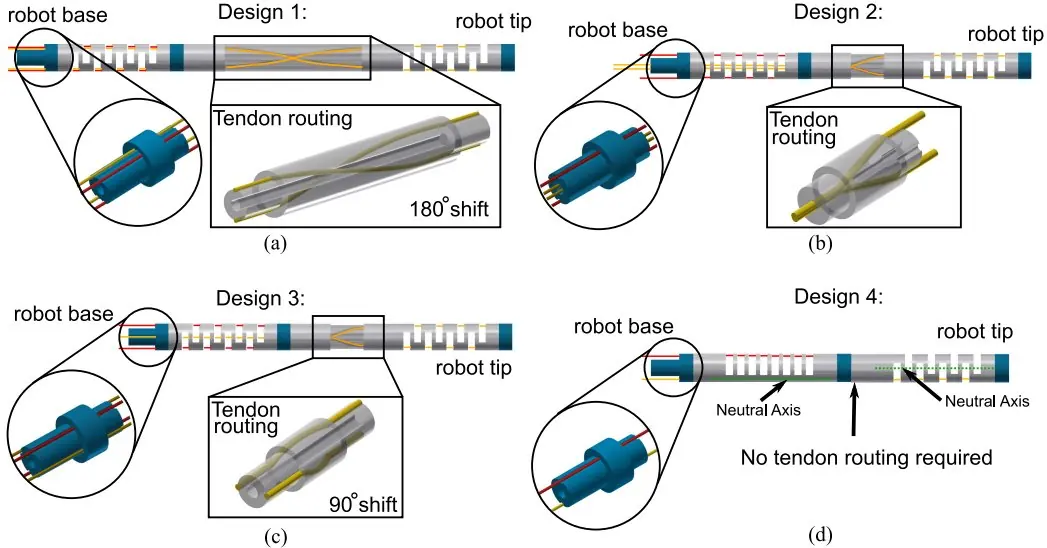
Design and Kinematics Analysis of a Robotic Pediatric Neuroendoscope Tool Body
Y. Chitalia, S. Jeong, N. Deaton, J. Chern, J. P. Desai
IEEE/ASME Transactions on Mechatronics · 2020
Patents
- Multi-DOF bending and bend-length control of a coaxially aligned robotically steerable guidewire (COAST) ↗RegisteredUS 12,752,086 · JP 7798789 · CN 115916317B · AU 2021259459 · US 19/795,936 (continuation) · EP 21793176.5 · CA/KR/PCT family
- Steerable and flexible robotic endoscopic tools for minimally invasive procedures ↗RegisteredUS 12,318,067 · US 12,557,970 (divisional) · JP 7730614 · CA 3,132,642 · EP 20766820.3 · PCT family