
Research Projects
Robotic Hands
Anthropomorphic hands with novel actuation, sensing, and skeletal structures.
Overview
The human hand is the most versatile manipulator known. We design anthropomorphic robotic hands that approach this versatility through novel actuation mechanisms, accurate joint kinematics, and integrated tension/force sensing.
Recent work includes the RIM Hand — a robotic hand with an accurate carpometacarpal joint and nitinol-reinforced skeletal structure — and earlier prosthetic hands such as the MSC Hand, driven by twisted string actuation.

Demonstrations
DDD Gripper — Direct-Drive Differential Multi-DOF Robotic Gripper
Simple Torque-Observation Alignment for Zero-Shot Sim-to-Real Grasping with a Direct-Drive Gripper
RIM Hand Test 2
RIM Hand Test 1
RIM Hand — Accurate Carpometacarpal Joint and Nitinol-Reinforced Skeleton
Flex RIM Hand — 1st Prototyping
Prosthetic Robot Hand controlled by EMG (Box and Block Test)
MSC Prosthetic Hand Prototype — EMG-based Grasping Intention Estimation
Webinar — High-Performance Anthropomorphic Prosthetic Hand Systems (KR)
Anthropomorphic Robot Hand with Active Dual-Mode Twisted String Actuation
Ph.D. work at KAIST
Representative Publications
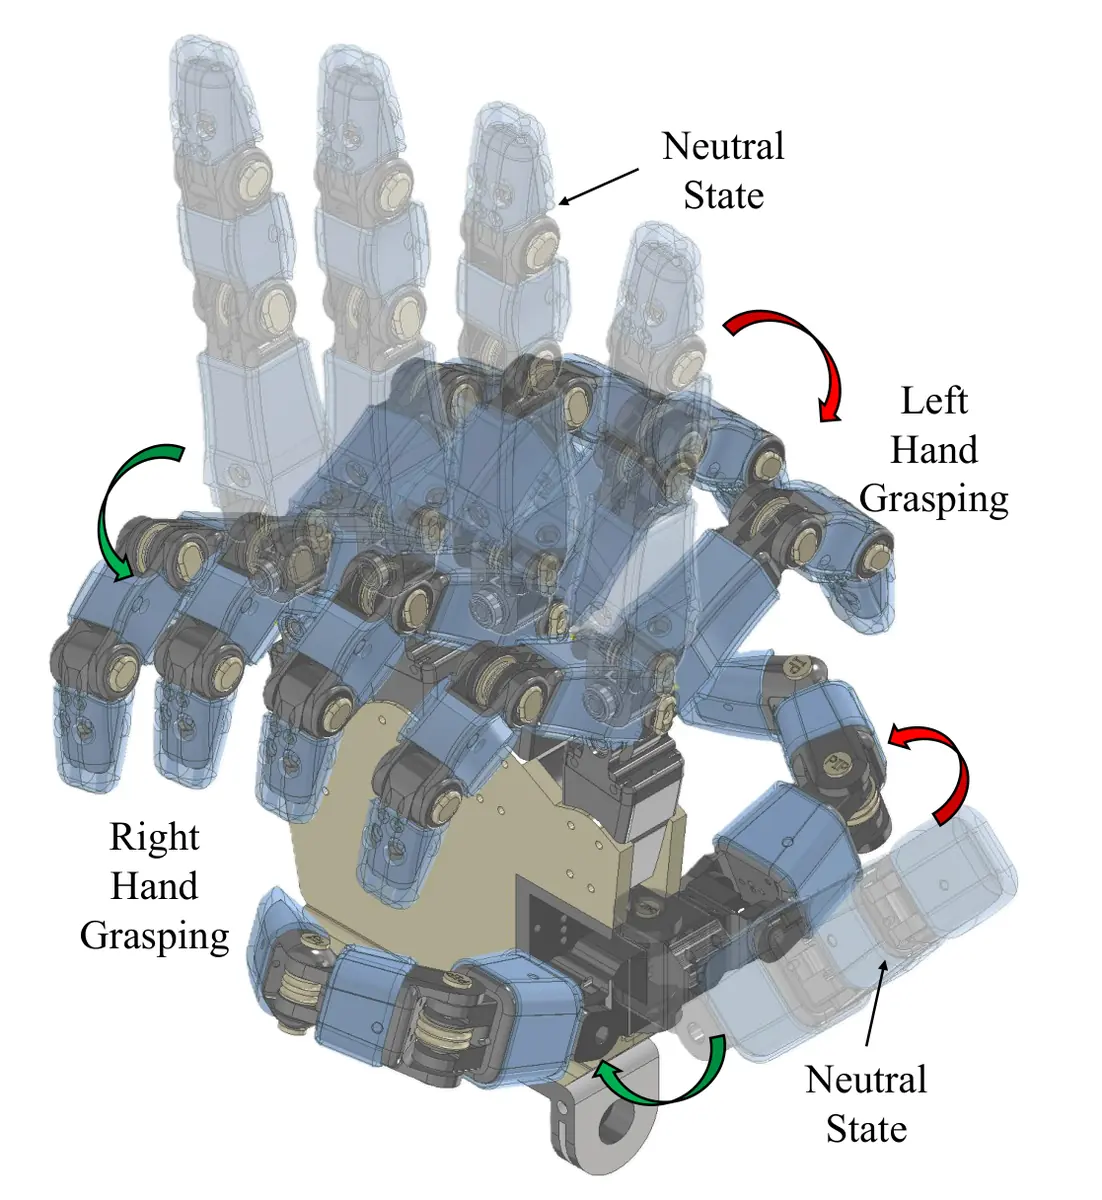
C. Lee, H. Kwon, S. Kim, S. Moon, S. Jeong*
arXiv preprint · 2026
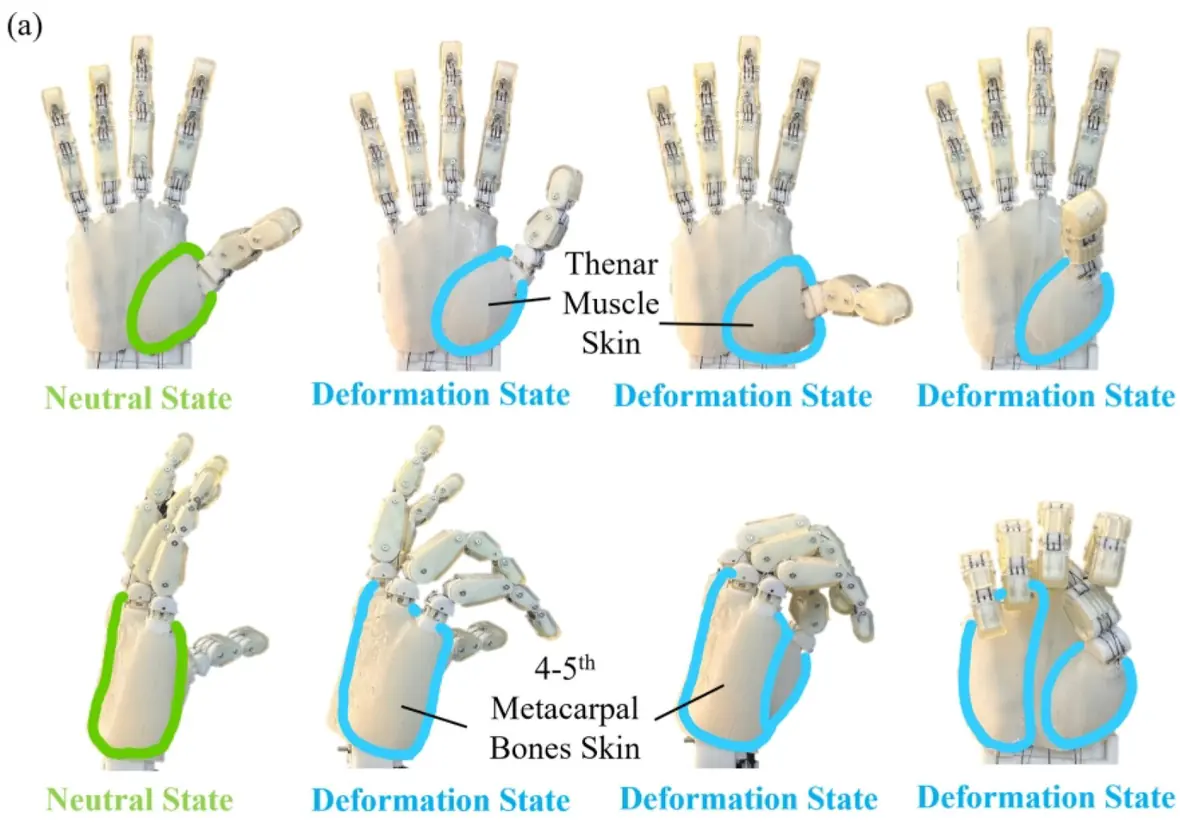
J. Lee, J. Han (co-first), D. Kim, S. Jeong*
Soft Robotics · 2026
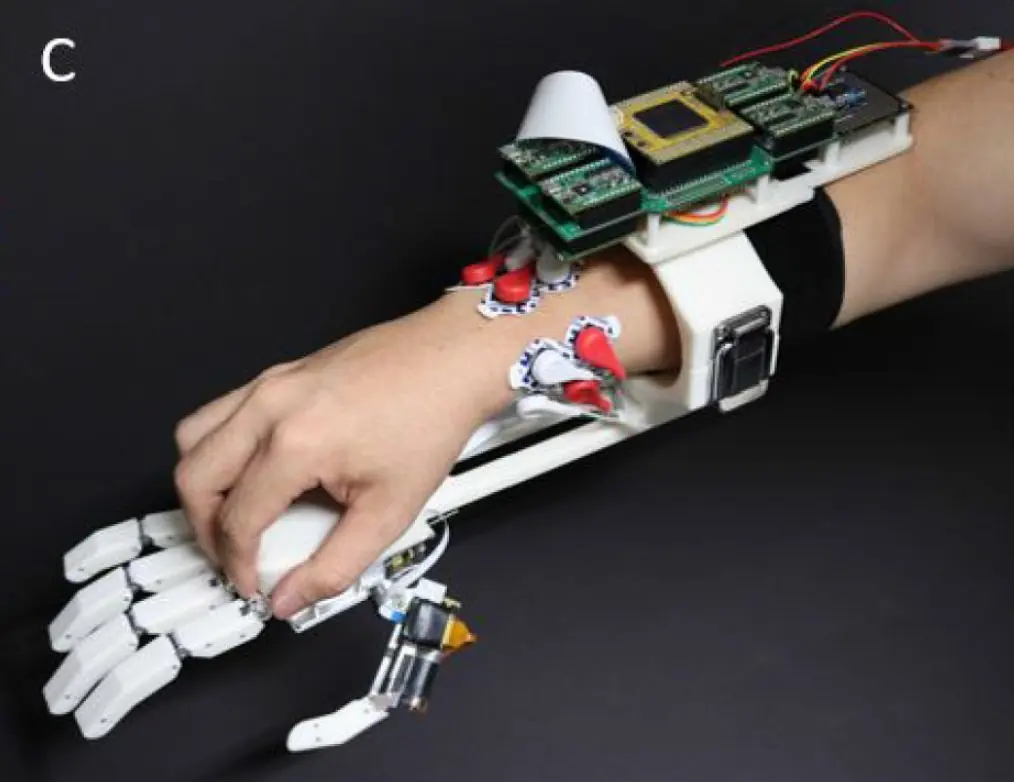
The MSC Prosthetic Hand: Rapid, Powerful, and Intuitive
Y. Cho, Y. Lee, P. Kim, S. Jeong*, K.-S. Kim*
IEEE Robotics and Automation Letters · 2022
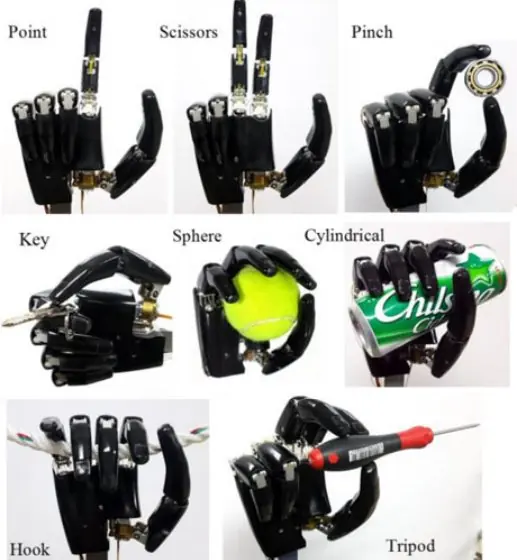
S. H. Jeong, K.-S. Kim, S. Kim
IEEE Robotics and Automation Letters · 2017
Patents
- Fingertip 3-axis force estimation from actuator current in a direct-drive differential mechanismFiledKR 10-2026-0177849
- Multi-DOF robotic gripper using a direct-drive differential mechanismFiledKR 10-2026-0005274 · PCT/KR2026/005769
- Quasi-direct-drive robot hand actuation with a nonlinear elastic mechanism and its controlFiledKR 10-2026-0075758 · KR 10-2025-0097452 · US 19/741,259 · JP 2026-174560 · DE 10 2026 130 079
- Flexible robot hand design method (CMC-joint robot hand)FiledKR 10-2025-0097414 · KR 10-2026-0118232
- Robot hand ↗RegisteredKR 10-2023-0181022
Funding
- NRF Materials Global Young Connect — high-dielectric elastomers for electroadhesive robotic end-effectors (2025.07 – 2028.12, 3.5B KRW; lead: Sogang, with KETI · GIST · Yonsei; intl. collaboration with UW-Madison and U. Louisville)