
Research Projects
Hand Exoskeletons
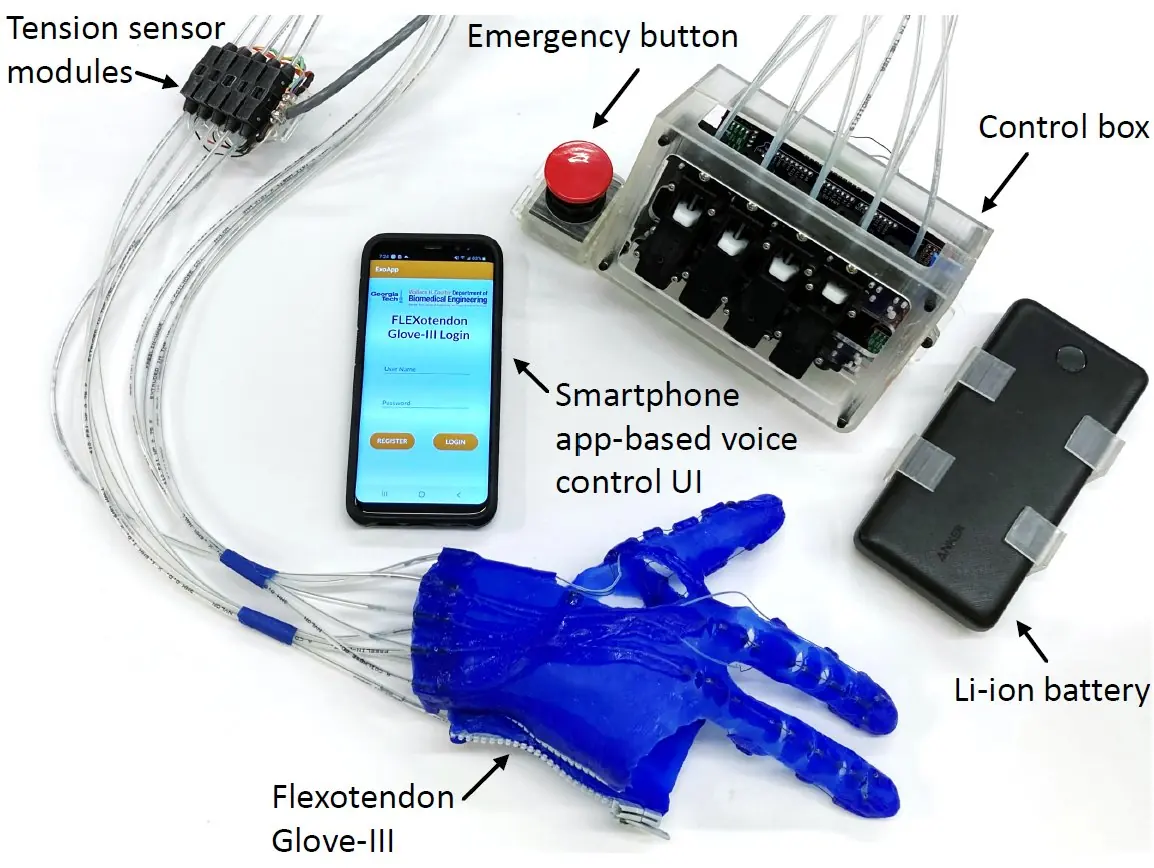
FLEXotendon Glove — soft wearable rehabilitation for spinal cord injury.
Overview
The FLEXotendon Glove series is a soft robotic hand exoskeleton for people with spinal cord injury: voice-controlled, tendon-driven, and patient-specific, with admittance grasping control and a novel fabrication method.

Demonstrations
FLEXotendon Glove-III
Work performed at Georgia Tech (Desai Lab) · © 2022 IEEE
Voice-Controlled FLEXotendon Glove-II for Spinal Cord Injury
Work performed at Georgia Tech (Desai Lab) · © 2020 IEEE
FLEXotendon Glove-II with Self-Sealing Suction Cups
Work performed at Georgia Tech (Desai Lab) · © 2020 IEEE
Hand Exoskeleton with Suction Cup
Work performed at Georgia Tech (Desai Lab)
Representative Publications
P. Tran*, S. Jeong, F. Lyu, K. Herrin, S. Bhatia, D. Elliott, S. Kozin, J. P. Desai
IEEE/ASME Transactions on Mechatronics · 2022
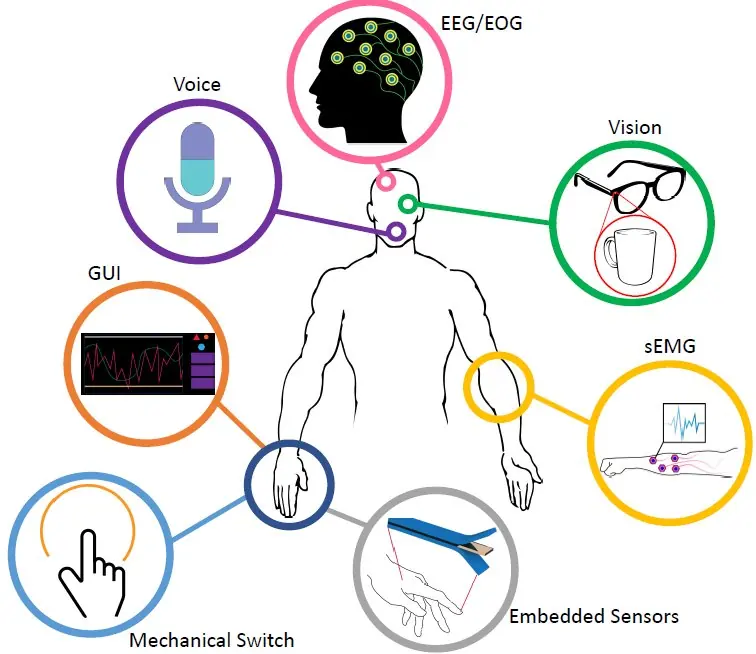
A Review: Hand Exoskeleton Systems, Clinical Rehabilitation Practices, and Future Prospects
P. Tran, S. Jeong (co-first), K. Herrin, J. P. Desai
IEEE Transactions on Medical Robotics and Bionics · 2021
Patents
- Voice-activated, compact, and portable robotic system ↗RegisteredUS 12,179,356 · US 12,576,517 (continuation) · JP 7411317 · EP 20766664.5 · CA 3,132,645 · PCT family